README
Flight Simulator
experimentNo. 0067categoryLabs & sensesrecordingpendingdataCC BY 4.0
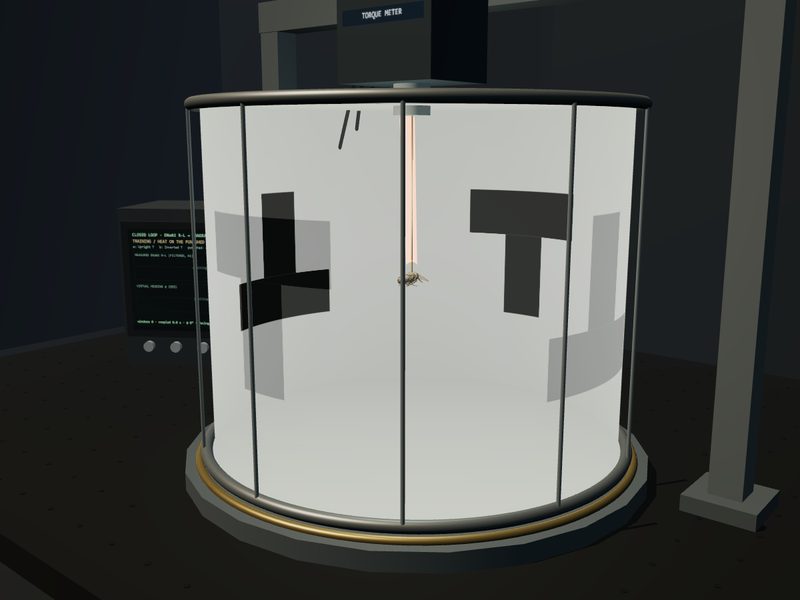
The fly is tethered to a torque meter inside a cylindrical panorama of four T patterns. In closed loop, its measured DNa02 right-minus-left rate turns the panorama while heat is paired with one pattern type.
Recording pending publication. Follow along for the release.
Setup
- Five phases: tether and torque meter (10 s), pretest without heat (24 s), training with heat on the punished pattern (36 s), test with heat off (24 s), performance index (12 s).
- Pattern pairs: upright / inverted T (the historical pair) or large / small T; the heated pattern type is selectable.
- Heat is a rendered infrared beam that switches on whenever a punished pattern is in front of the fly during training.
- Loop control: closed loop (measured) or open loop (pre-programmed schedule); gain 0–12 °/s/Hz, default 4; low-pass filter τ default 0.4 s.
- Cameras: Flight simulator / rig, Arena / looking in, Tethered fly, Fly POV / panorama, Readout screen.
Measurement
- Canonical retinal input in 200 ms live windows; measured readouts are DNa02, HS + H2 and EPG.
- In closed loop each measured window turns the panorama by −gain × filtered (DNa02 R − L) × Δ; in open loop the panorama follows a pre-programmed experimenter schedule and measured output is only displayed.
- An optional, bounded direct VP2 warming drive (0.1–1.2) accompanies heat-on windows; it is off by default.
- Performance index per phase: PI = (t unpunished − t punished) / (t unpunished + t punished), from measured closed-loop windows.
Limitations
- Neural weights are fixed, so no learning can occur; the performance index reports fixed-weight visuomotor bias.
- The 32-column retina has no elevation, so upright and inverted T produce identical column profiles.
- The DNa02 asymmetry stands in for yaw torque; the protocol is condensed from Heisenberg and Wolf's flight simulator.